Hironmoy Roy Rudra

I build the infrastructure behind robotics research: simulation environments, capture and annotation pipelines, evaluation campaigns and reproducible setups.

BSc Computer Science, BRAC University, Dhaka. Expected graduation January 2027. Available remotely from January 2027.

Research Engineer CV (PDF) hironmoy5458@gmail.com github.com/Rudra-roy linkedin.com/in/hironmoy-roy-rudra
The Mongol-Tori rocker-differential rover on a synthetic heightfield, rendered from its Fusion 360 CAD
Interactive: the Mongol-Tori rocker-differential rover, from the Fusion 360 CAD used in rocker-loop-sim, driving a synthetic heightfield; the rockers, connecting rods and differential bar follow the ground. Drag or use the arrow keys to orbit.

About

Computer Science undergraduate at BRAC University building the infrastructure behind robotics research: simulation environments for Isaac Sim and Unreal Engine 5/Cosys-AirSim, in-vehicle capture and annotation pipelines for a multimodal driving dataset, a scored evaluation campaign, benchmark tooling, and a pinned, checksum-verified setup script that fails unless it reproduces the reported run.

Work spans ROS 2 autonomy stacks (C++, Python), event-camera synthesis and a multi-seed training suite, backed by test suites (289 tests in hifi-environment-builder), licence gates and per-file provenance.

Current work

CERTUS stack

In preparation

research infrastructure for an IROS 2027 submission · first author

Sim-first terrain stack: ZED 2i depth to uncertainty-aware elevation layers, TOPP-RA profiles with path-varying limits, Isaac Sim 6 scenes for three Clearpath platforms, and a checksum-pinned setup that fails unless it reproduces the reported run.

Grid search and model-predictive horizon An occupancy grid with obstacle cells. A search frontier expands cell by cell from the start until it reaches the goal, a smoothed path draws itself through the explored cells, and a short horizon of predicted rover footprints slides along the path.
Planning sketch drawn for this page: an occupancy grid, a search frontier, the path it finds and a short predictive horizon; not a figure from any manuscript.

COVE environments

In preparation

five environment families for the COVE dataset (NeurIPS 2027 Datasets & Benchmarks track)

Label-correct, sensor-clean industrial environments built with hifienv in Unreal Engine 5, with seeded layouts, QC gates and event plus RGB capture.

Event-camera stream against frames A sensor frame on the left with a dark object crossing it. On the right a time axis fills with small on and off event ticks in bursts as the object's edges cross pixels, dense where it moves fast and sparse where it is slow, above a second axis with a few evenly spaced frame ticks. sensor events on off frames t t
Event-camera sketch drawn for this page: a moving object produces asynchronous ON and OFF events, against the sparse ticks of a frame camera; not a figure from any manuscript.

DhakaSense stack

Under review

capture, sync and annotation pipeline behind an ICRA 2027 submission · second author

In-vehicle recording with INS master clock and sync validation, PPK trajectories, remote export that hashes data where it lives, and semi-automatic 3-D labelling into the LiDAR cloud.

Projects

hifi-environment-builder (hifienv)

Public code

Oct 2026

  • Python
  • Unreal Engine 5
  • Cosys-AirSim
  • Isaac Sim
  • USD
  • Blender

Python toolkit and Claude Code skill that builds label-correct, sensor-clean, licence-clean, reproducible simulation environments for Unreal Engine 5 / Cosys-AirSim and Isaac Sim / USD from CC0 and CC-BY assets with provenance; parity, null-test and licence gates; 289 tests.

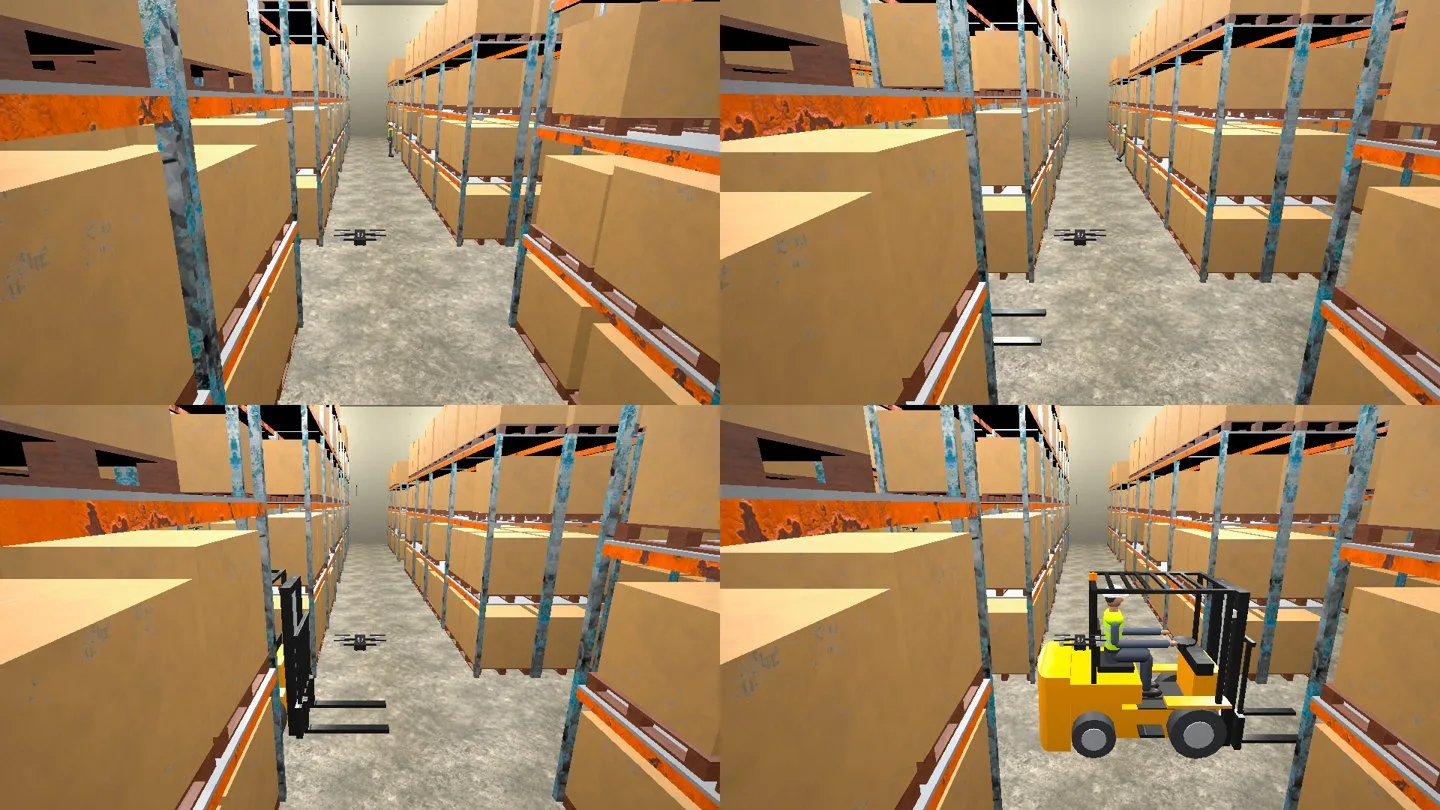
Four renders of the same warehouse aisle with placed hazards: dropped pallets, a drone, a forklift and a person between the racking
One warehouse aisle, four hazard placements.
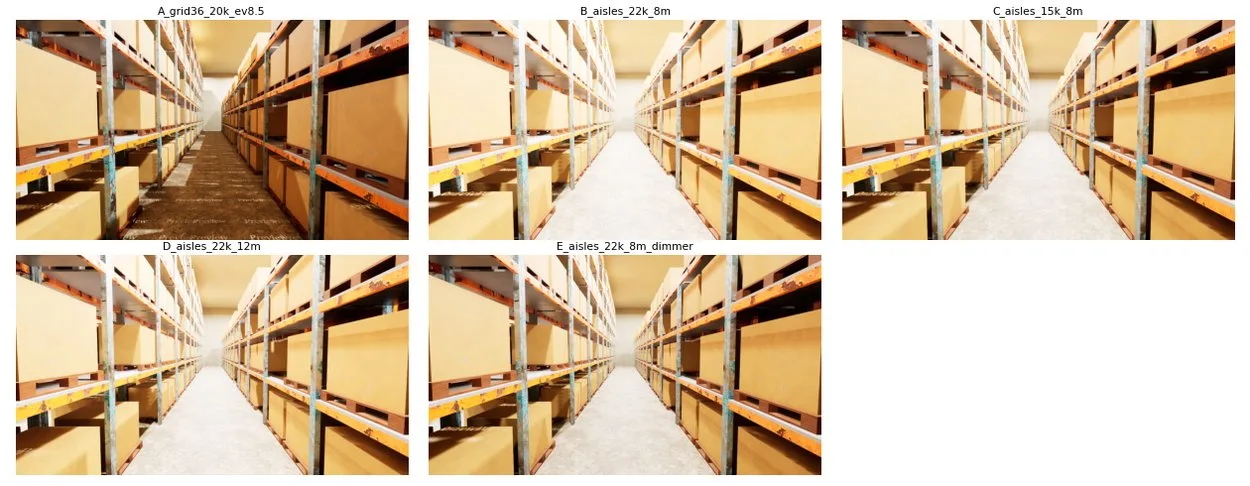
Five lighting variants of one warehouse aisle, each labelled with its variant name
Five lighting variants of the same aisle.

CERTUS navigation stack

Sep 2026 – present

  • ZED 2i
  • elevation_mapping_cupy
  • TOPP-RA
  • cvxpy
  • Isaac Sim 6.0.1
  • ROS 2 Jazzy

Sim-first research stack behind CERTUS: ZED 2i stereo depth through elevation_mapping_cupy to slope, roughness and uncertainty layers; TOPP-RA (cvxpy) velocity profiles whose limits vary along the path; Isaac Sim 6.0.1 scenes for Clearpath Husky, Jackal and Warthog; a ROS 2 Jazzy container; and a staged, idempotent setup script that pins every dependency by checksum and fails unless it reproduces the reported run.

BARN Challenge 2027 preparation

Public code

Jul – Aug 2026

  • ROS 2 Jazzy
  • C++
  • Clearpath Jackal
  • 2-D LiDAR
  • MPC as a QP at 30 Hz

Full classical autonomy stack for the ICRA BARN Challenge (Clearpath Jackal, 2-D LiDAR, hidden obstacle worlds): online occupancy and distance field, A*, elastic band, sequentially linearised MPC solved as a QP at 30 Hz, safety shield, recovery; ROS 2 Jazzy, C++; a 500-trial campaign protocol on the BARN 2026 public 50-world suite; a nine-chapter tutorial and a live site with seven interactive demos.

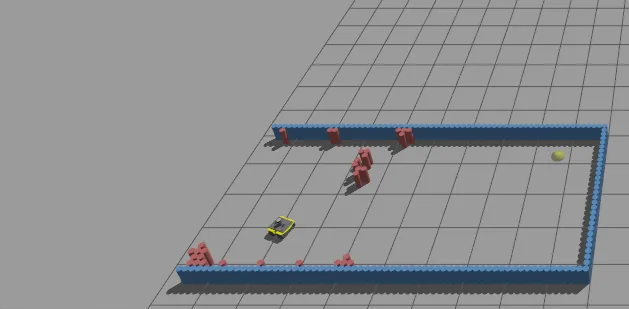
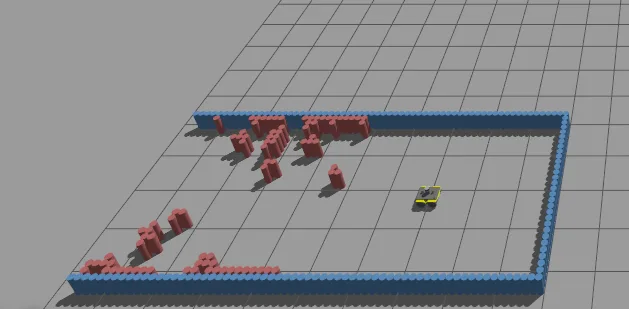
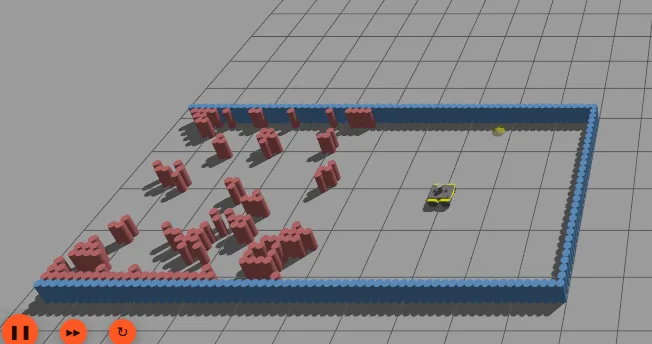
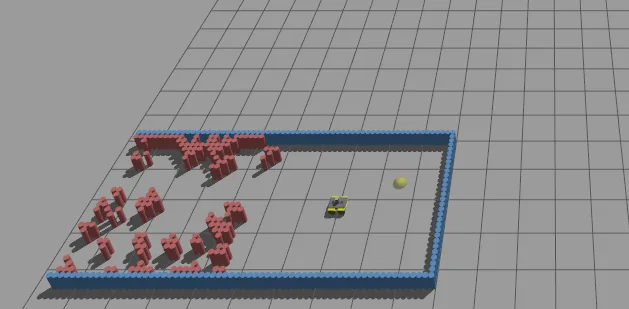
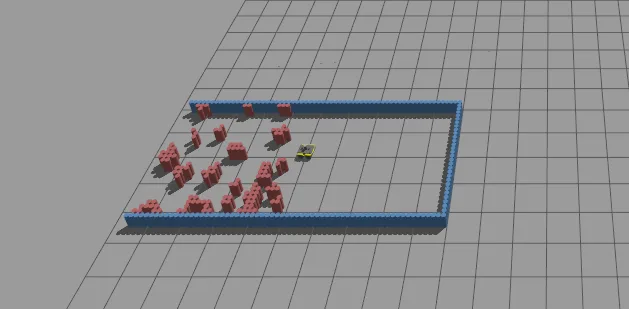
BARN world 5: the Jackal in a walled arena with a sparse scatter of red block obstacles, viewed from above in simulationBARN world 32: a denser arrangement of red block obstacles inside the walled arenaBARN world 62: clustered red block obstacles forming narrow passages in the arenaBARN world 155: red block obstacles arranged along the arena's lengthBARN world 299: a tight obstacle field near the arena's far wall
Worlds 5, 32, 62, 155 and 299 of the BARN 2026 public 50-world suite.

DhakaSense capture and annotation stack

Jul – Sep 2026

  • ZED SVO2
  • RealSense
  • SBG Ellipse-D INS
  • RTKLIB PPK
  • CVAT
  • NFS

In-vehicle recording stack with supervisor and watchdog, PPK-corrected INS trajectories, a remote export pipeline that hashes hundreds of GB where they live, and a semi-automatic 3-D labelling pipeline lifting foundation-model segmentation into the LiDAR cloud. Private repository.

evs-bench

Jul – Sep 2026

  • Python
  • ESIM event synthesis
  • YOLO11
  • SORT
  • AirSim

Event-based surveillance benchmark tooling: corrected ESIM event synthesis, class-agnostic RGB and event detector baselines, dt-aware SORT tracking and a time-to-first-detection metric; now the capture infrastructure behind COVE. Private repository.

PEFT multi-seed retraining suite (TSDLoRA, LoRA, AdaLoRA)

2026

  • PyTorch
  • peft
  • Optuna
  • GLUE
  • Wilcoxon tests

Three-stage pipeline behind the thesis experiments: Optuna/TPE hyperparameter search, multi-seed retraining of 3 methods × 3 backbones × 8 GLUE tasks (72 combinations, 5 seeds each) through a CLI or a web portal, and an analysis stage producing mean ± std tables, single-signal ablations and Wilcoxon tests.

Publications and manuscripts

Listed by title only: no PDFs, and no figures, from manuscripts under review or in preparation. No author lists for unpublished work.

Matched Controls for Probe-Based LoRA Rank Allocation: A Negative Result for One Allocator under a Rank-Coupled Initialization

Under review

Transactions on Machine Learning Research, first author

Five-seed, budget-matched comparison of a probe-based rank allocator against uniform-rank LoRA, LoRA and GoRA on eight commonsense tasks across three decoders plus 11 of 24 GLUE cells; the allocator trails the matched control in 26 of 35 cells.

DhakaSense: A Multimodal Driving Dataset and Benchmark for Dense, Heterogeneous Traffic in Dhaka

Under review

IEEE ICRA 2027, second author

14 h 35 min across 175 scenes from a Livox Mid-360, stereo depth, six RGB cameras and post-processed GNSS/INS, with CNG auto-rickshaws and cycle rickshaws as 3D classes and every metric reported per traffic-density level.

CERTUS: Certified Terrain Traversal Under Sensing Uncertainty, with Certification-Driven Active Perception

In preparation

IEEE/RSJ IROS 2027, first author

A rover drives only on ground it has certified: step, slope and body clearance pass with a distribution-free margin on the map's own uncertainty; a decidability rule predicts which depth sensor can certify which rover; when nothing ahead is certified, active perception picks the viewpoint that resolves the most blocking cells per second. Validated in Isaac Sim before deployment on a real rover.

COVE-Sim: counterfactual, recipient-specific communication for event-camera UAV teams (working title)

In preparation

IROS 2027, first author

The first collaborative-perception system whose shared representation is event-derived, with a counterfactually supervised, recipient-specific gate deciding what crosses the link; simulation study in Unreal Engine 5.8 / Cosys-AirSim.

COVE multi-UAV hazard detection and avoidance dataset (working title)

In preparation

NeurIPS 2027 Datasets & Benchmarks track, collaboration

Five industrial environment families with seeded layouts, exact label geometry, QC gates and rule-breaking hazard speeds, captured with event and RGB cameras.

Experience and honours

  • Education

  • BSc Computer Science, BRAC University, DhakaSep 2022 – Jan 2027 (expected)
  • Higher Secondary Certificate, Science, National College of Education, Narsingdi2019 – 2021
  • BRACU Mongol-Tori (University Mars Rover Team)

  • Co-AdvisorNov 2025 – present
  • Autonomous Sub-Team LeadSep 2024 – Aug 2025
  • Control Systems EngineerFeb – Aug 2024
  • ContributorNov 2023 – Feb 2024
  • Elsewhere

  • Kibo Robot Programming Challenge, 6th edition (JAXA): 6th place, national roundAug 2025 – Feb 2026
  • First Global Challenge Team Bangladesh: Technical MentorSep 2024 – Feb 2025
  • ROBO hobby: AI Engineer, edge computing for agricultureOct 2024 – Jan 2025
  • Robotics Club of BRAC University: Student Instructor, ROS, Gazebo and WebotsOct – Nov 2025
  • Honours

  • 8th place, University Rover Challenge 2025 (The Mars Society, Utah)
  • 21st place, University Rover Challenge 2024
  • VC's List ×4 and Dean's List ×3, BRAC University

CV

The CV and this page say the same things; the CV has the detail.